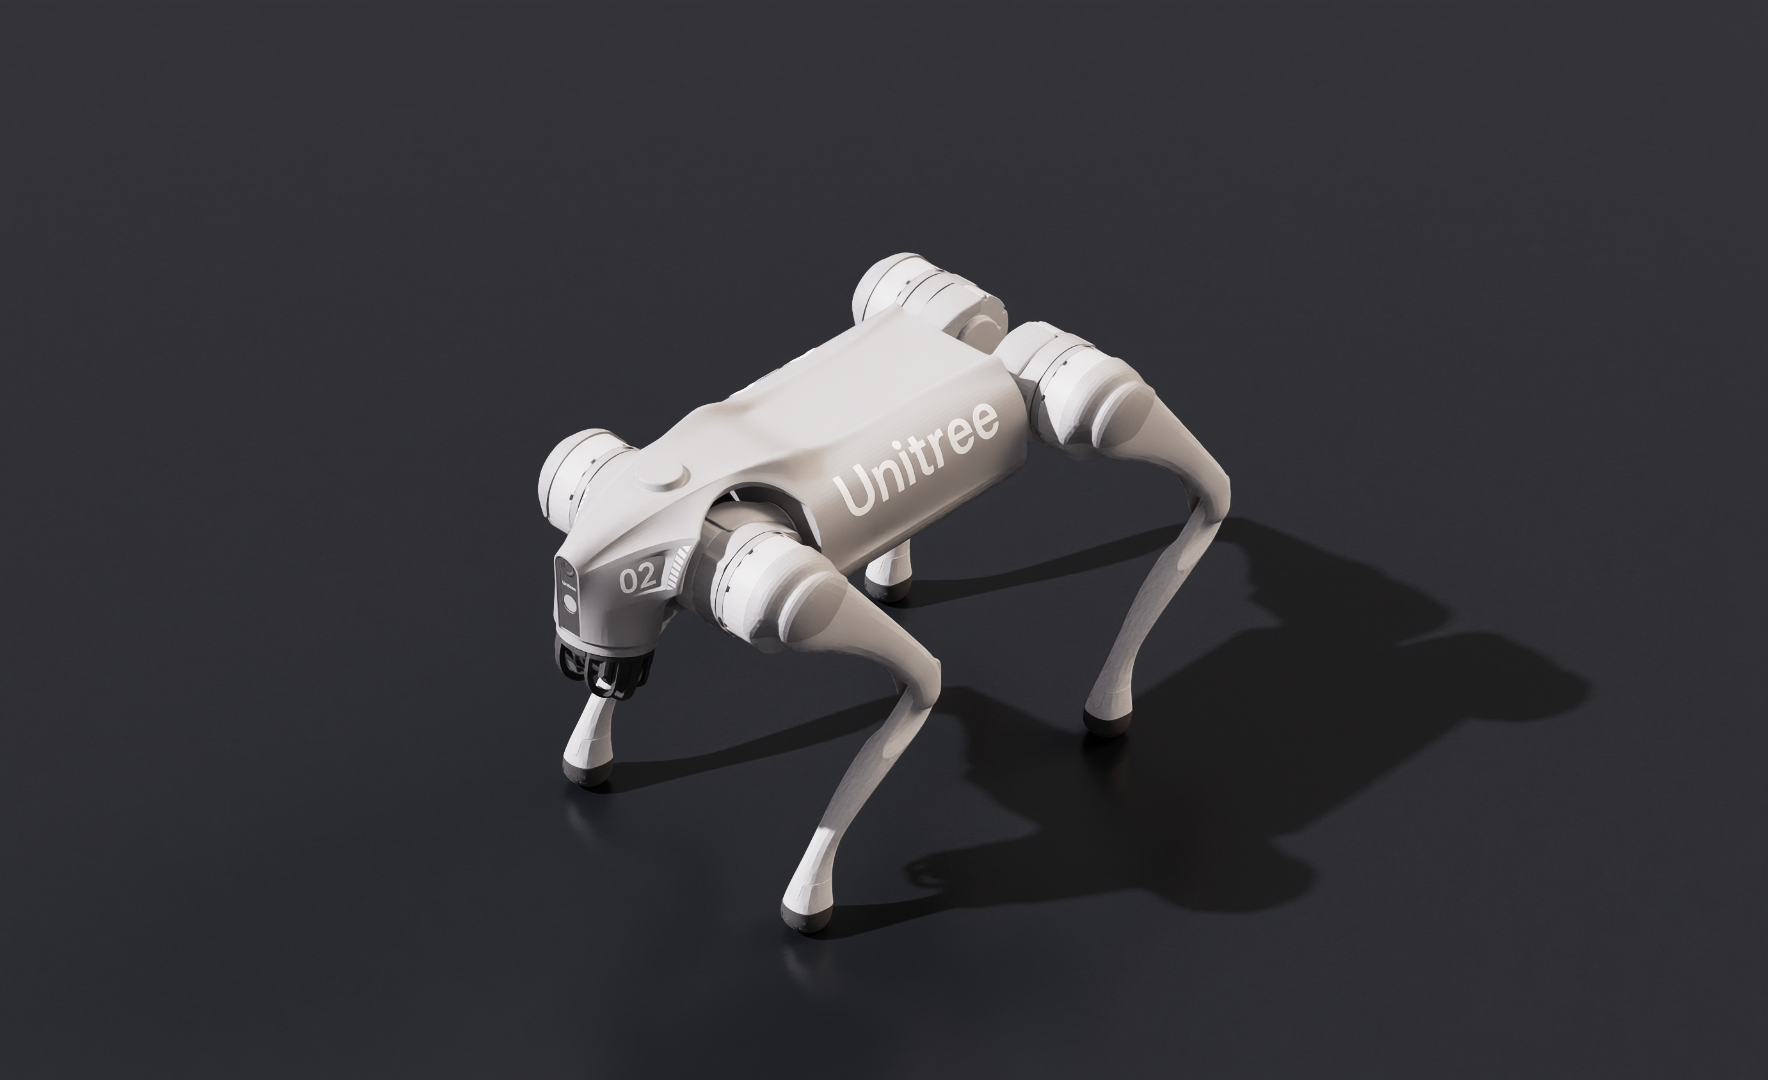
 Still in development
Quadrupedal Machine Learning Walker
Machine Learning · Ongoing
- Role
- Independent Researcher
- Timeline
- Aug 2026 – Present
- Team
- Solo project
- Tools
- Python, Reinforcement Learning
Teaching a Unitree Go2 quadruped to walk across a virtual environment with reinforcement learning, as a hands-on way to build intuition for how RL works.
The Problem
I wanted to build intuition for how reinforcement learning works, beyond just following tutorials. Getting a quadruped to walk is a useful test: success or failure is visible immediately, and with four legs to coordinate, balance and gait make the training setup matter.
My Approach
I'm training a Unitree Go2 quadruped model to walk through a virtual environment by defining and iterating on reward functions, and watching how each change shapes its gait. It's a solo project, and I'm treating it as ongoing learning rather than a single deliverable.
Outcome
Still in development. I've got more planned over the next year as I extend what the Go2 can do and refine the reward design.