 Still in development
Custom Cycloidal Gearbox Robotic Arm
CAD · Mechatronics · Ongoing
- Role
- Sole Designer & Engineer
- Timeline
- Sep 2025 – Present
- Team
- Solo project
- Tools
- Fusion 360, C++, Arduino, 3D Printing, Custom PCB/Protoboard Design
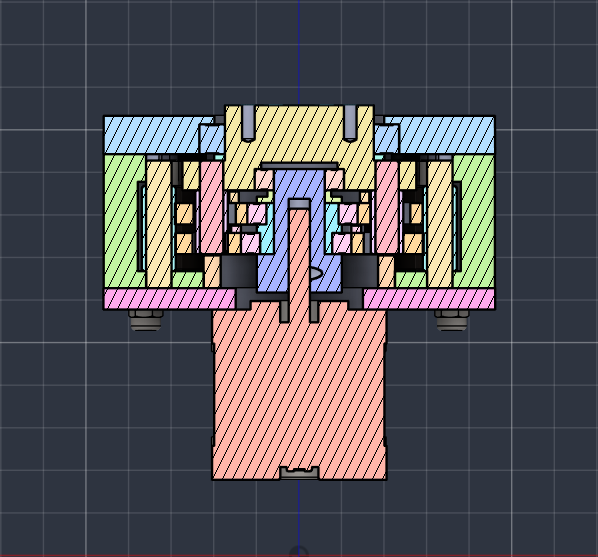
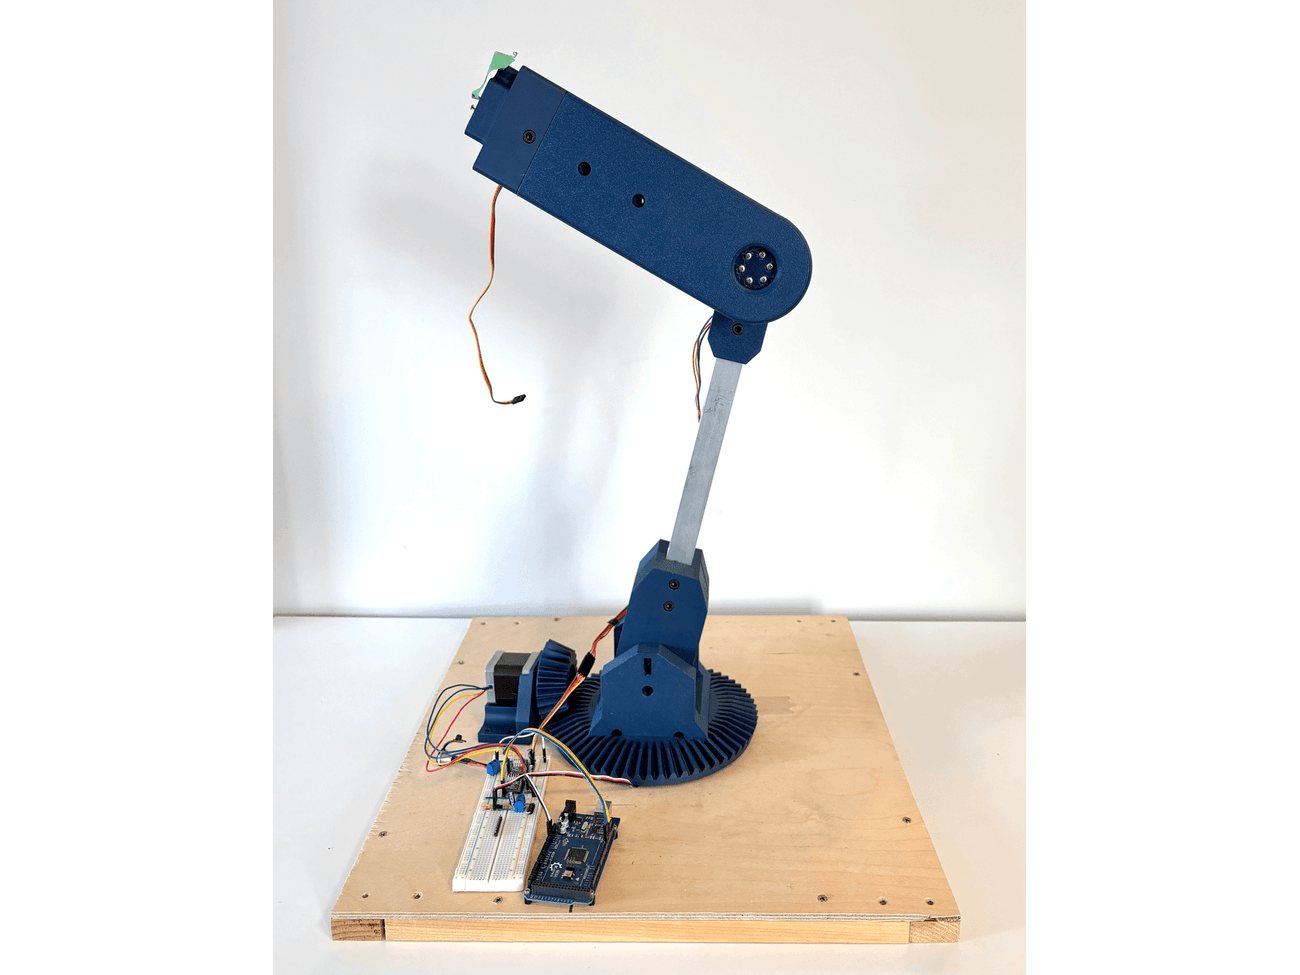
Designing a custom robotic arm around a self-designed 19:1 cycloidal gearbox built for high torque and low backlash.
The Problem
I wanted to design a robotic arm from first principles instead of bolting together off-the-shelf actuators. That meant engineering the gearbox, structure, and electronics myself, and getting real experience with high-torque, low-backlash actuation.
My Approach
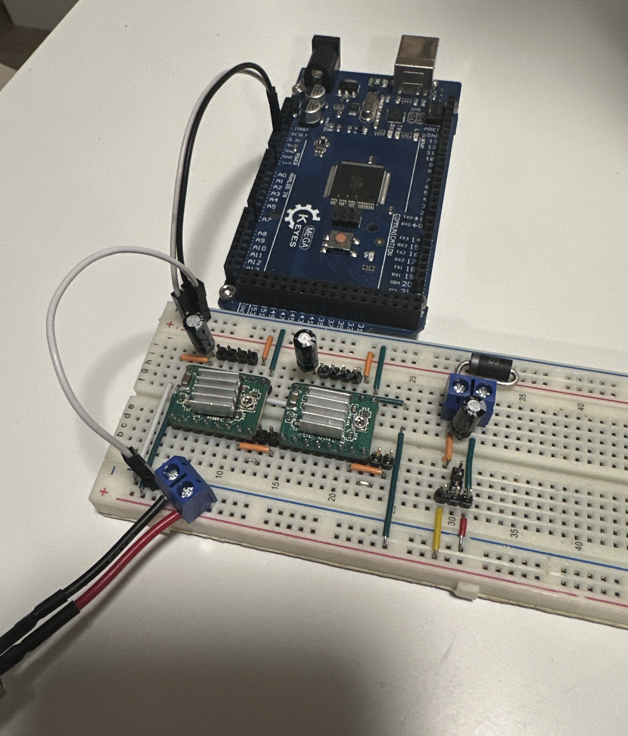
I modeled every component in Fusion 360 with manufacturability in mind, and designed the 19:1 cycloidal gearbox for compact, high-torque, low-backlash actuation. I backed it with shear, bending, and torque calculations before 3D printing anything. On the electronics side, I wrote the C++ stepper motor control logic for an Arduino and hand-soldered custom driver boards on protoboard, then 3D-printed the structural parts and iterated based on how they actually performed.
Outcome
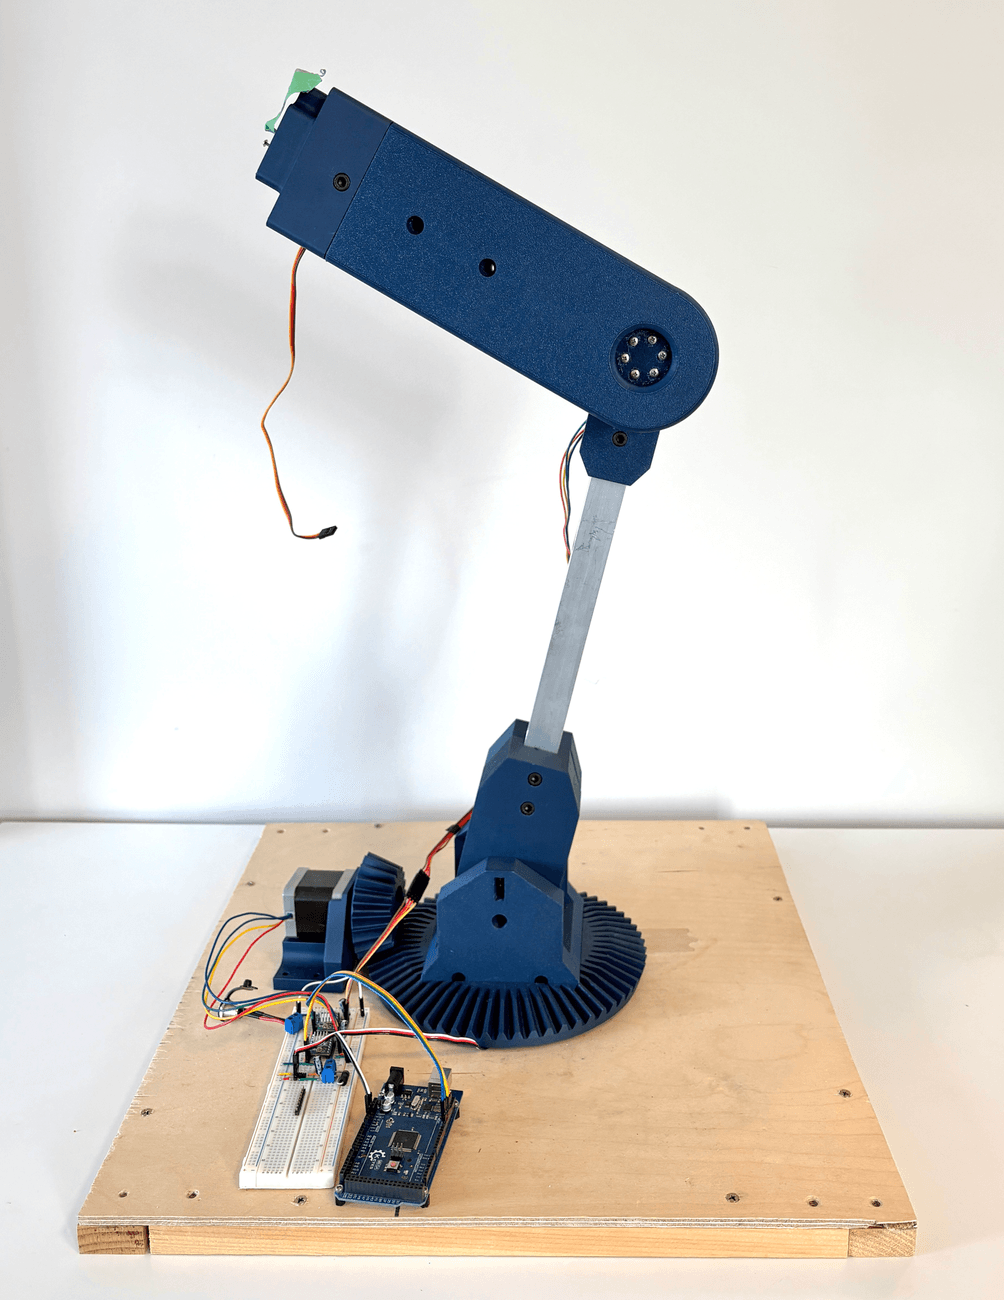
The project is ongoing. I'm currently developing the end articulator and its controller code, working toward a modular arm for pick-and-place tasks, demos, and other projects down the line.