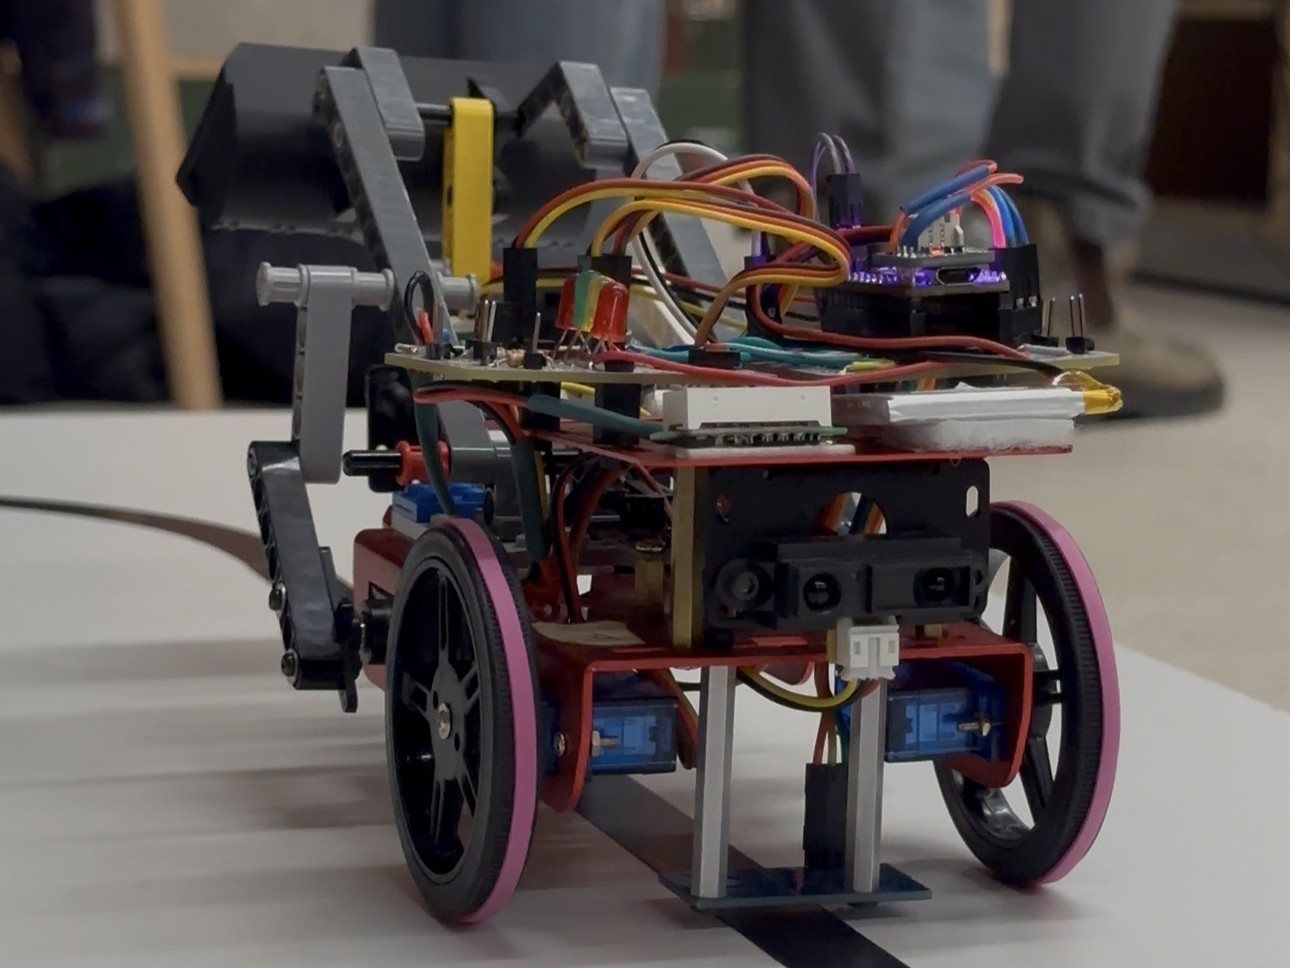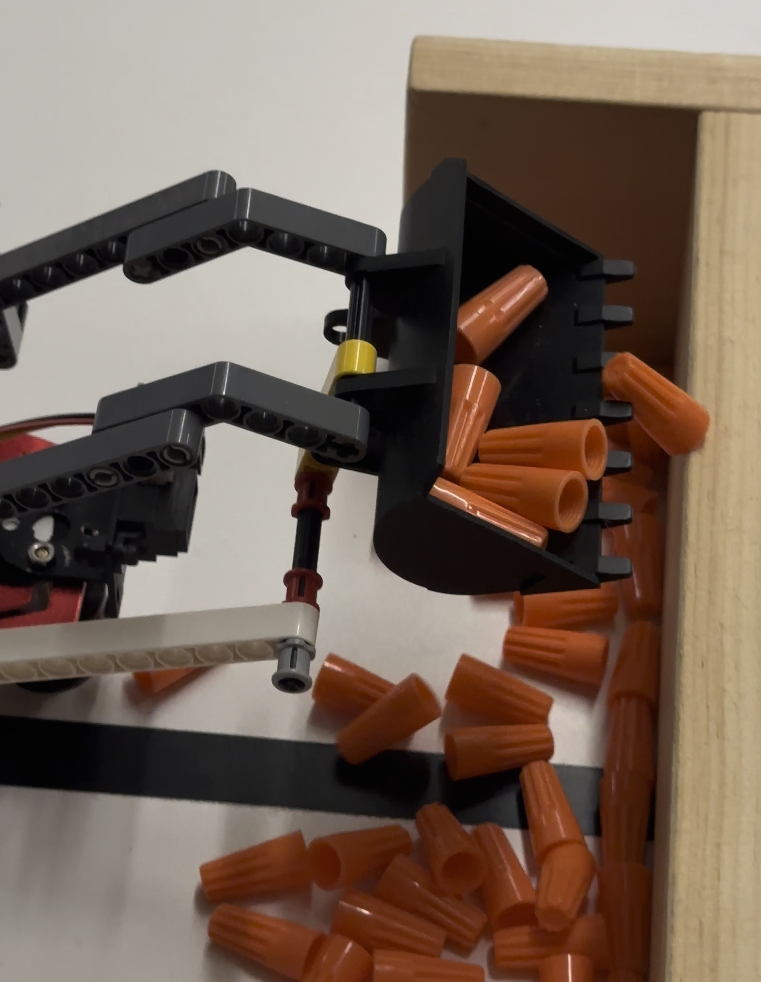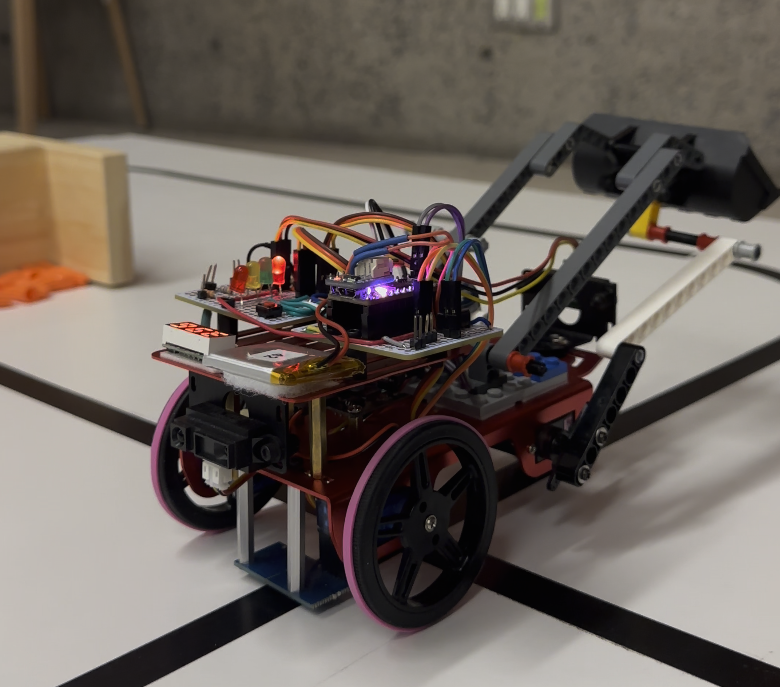
Line-Following Autonomous Skidsteer
Controls · Autonomous Systems · 2025
- Role
- Controls Programmer
- Timeline
- Jan 2025 – Apr 2025
- Team
- Team of 2
- Tools
- PI Control, Sensor Integration, Embedded Programming
Programmed an autonomous skidsteer that follows a track, turns at track divisions, and picks up and drops off objects using a tuned PI controller.
The Problem
For MREN 103, the assignment was an autonomous skid-steer robot. It had to follow a defined track, take turns correctly at track divisions, and pick up and drop off objects at set locations, with no operator input.
My Approach
I split the work with one teammate. I programmed the control logic that reads the robot's exteroceptive sensors to track the line, and built a PI controller to apply corrective steering whenever it drifted off course.
Outcome
The skidsteer followed the line, took the turns at each division, and completed the pickup-and-dropoff task as specified.
Track Demo
A recreation of the actual competition track: the skidsteer follows the loop clockwise, detours into the pickup bay to grab objects, carries them around to the drop-off bay, and repeats. Like the real robot's Sharp IR sensors, each one only senses in the 150° cone ahead of it. Move your cursor into that cone and it stops until you leave. Add more robots and they queue for the bays and hold a safe gap.